Track C, rung C1 (Voronoi methods plan): the FACE mesh of a published tessellation — one record per geometric face (an interior face appears in two cells' facet lists; the mesh keeps it once, owned by the lower cell), with the geometry the finite-volume operators need, and a cell → faces CSR with the orientation sign. Built on device from TessellationView + AuxMaps. More...
#include <Kokkos_Core.hpp>#include <string>#include "peclet/core/common/view.hpp"#include "peclet/voro/tessellation_view.hpp"#include "peclet/voro/transpose.hpp"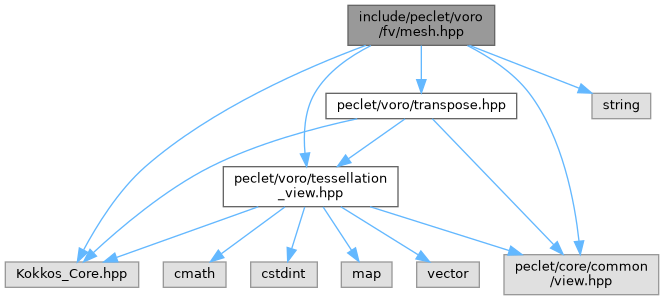
Go to the source code of this file.
Classes | |
| struct | peclet::voro::fv::FaceMesh< Real > |
Namespaces | |
| namespace | peclet |
| namespace | peclet::voro |
| Device-native Voronoi tessellation, geometry and finite-volume physics. | |
| namespace | peclet::voro::fv |
Functions | |
| template<class Real > | |
| FaceMesh< Real > | peclet::voro::fv::buildFaceMesh (const TessellationView< Real > &view, const AuxMaps< Real > &aux, int nOwned=-1) |
Detailed Description
Track C, rung C1 (Voronoi methods plan): the FACE mesh of a published tessellation — one record per geometric face (an interior face appears in two cells' facet lists; the mesh keeps it once, owned by the lower cell), with the geometry the finite-volume operators need, and a cell → faces CSR with the orientation sign. Built on device from TessellationView + AuxMaps.
Voronoi orthogonality is the whole point of this track: the connector between the two seeds is perpendicular to the face, so the two-point flux (p_B − p_A)/d is consistent with no non-orthogonal correction, and the pressure Laplacian is the graph Laplacian A_f/d_f that the OT optimiser already assembles. The only mesh-quality error left is SKEWNESS — the face centroid off the connector — which the centroidal energy term of track B minimises.
Face geometry from the view (Voronoi planes; a power tessellation's connector is the same vector but the seed distance is not |conn| — pass positions when that matters): area vector A (owner side, outward), connector r = 2n (owner seed → plane foot, doubled = to the neighbour seed), dV/dr = (|A|/|r|)(r − c) ⇒ face centroid c = r − dV·|r|/|A| (owner-relative).
